Runway unveils Praxis-1 open-weight world action model for robotics
Tags Hardware · Research · Startups
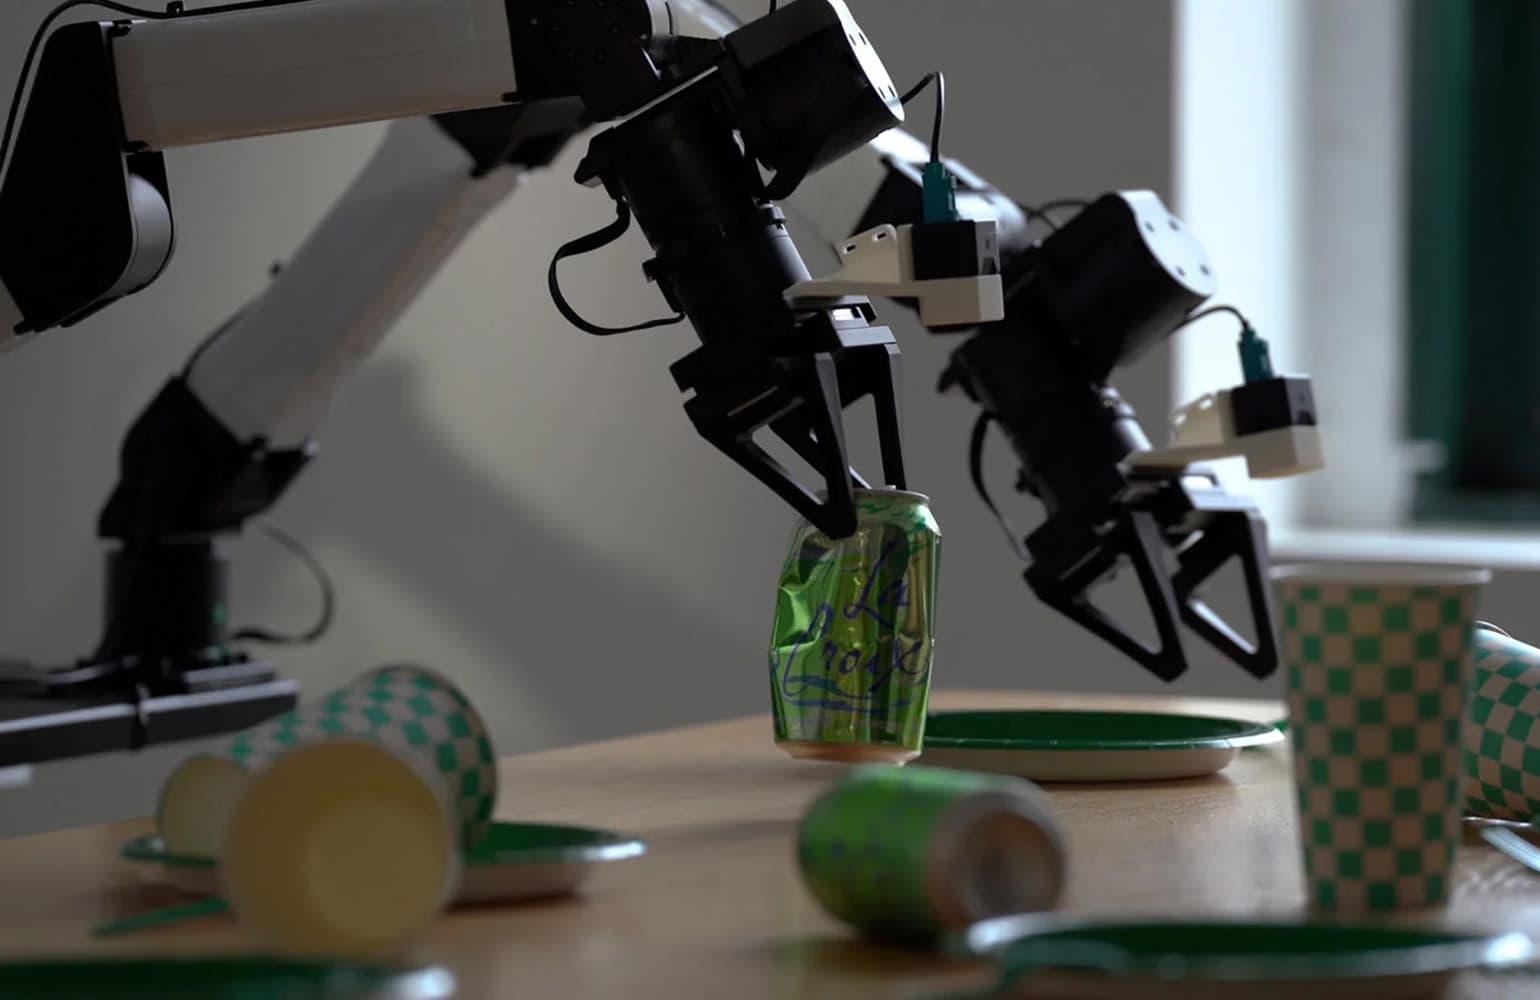
Runway introduced Praxis-1, an open-weight world action model that turns its large-scale video pretraining into robot control, now being tested with Noble Machines, Standard Bots and Ultra ahead of a public release. Runway reports that simulating robot policies inside its world model predicts real-world results with 0.95 correlation, and that after fine-tuning, web-video pretraining gave 16.1 cm final placement error versus 16.0 cm for teleoperated robot video across 93 evaluation pairs. Early partners are running Praxis-1 on their own hardware, with a public release and open weights planned in coming months. The model was trained on manipulation tasks from pick-and-place to deformable-object tasks such as packing gift bags.
Technical significance
Praxis-1 tests whether abundant third-person video can substitute for scarce robot teleoperation data, a core bottleneck in robot learning. The reported 0.95 correlation between simulated and real-world policy outcomes, if it holds under independent testing, would make world-model simulation a cheaper way to evaluate robot policies before deployment. The open-weight release plan could lower the barrier for robotics startups, though Runway notes that video alone does not capture joint angles or grip force, so robot-specific fine-tuning remains necessary.